Training Drones to Spot Tanks: The Aerial Dataset Problem Nobody Talks About
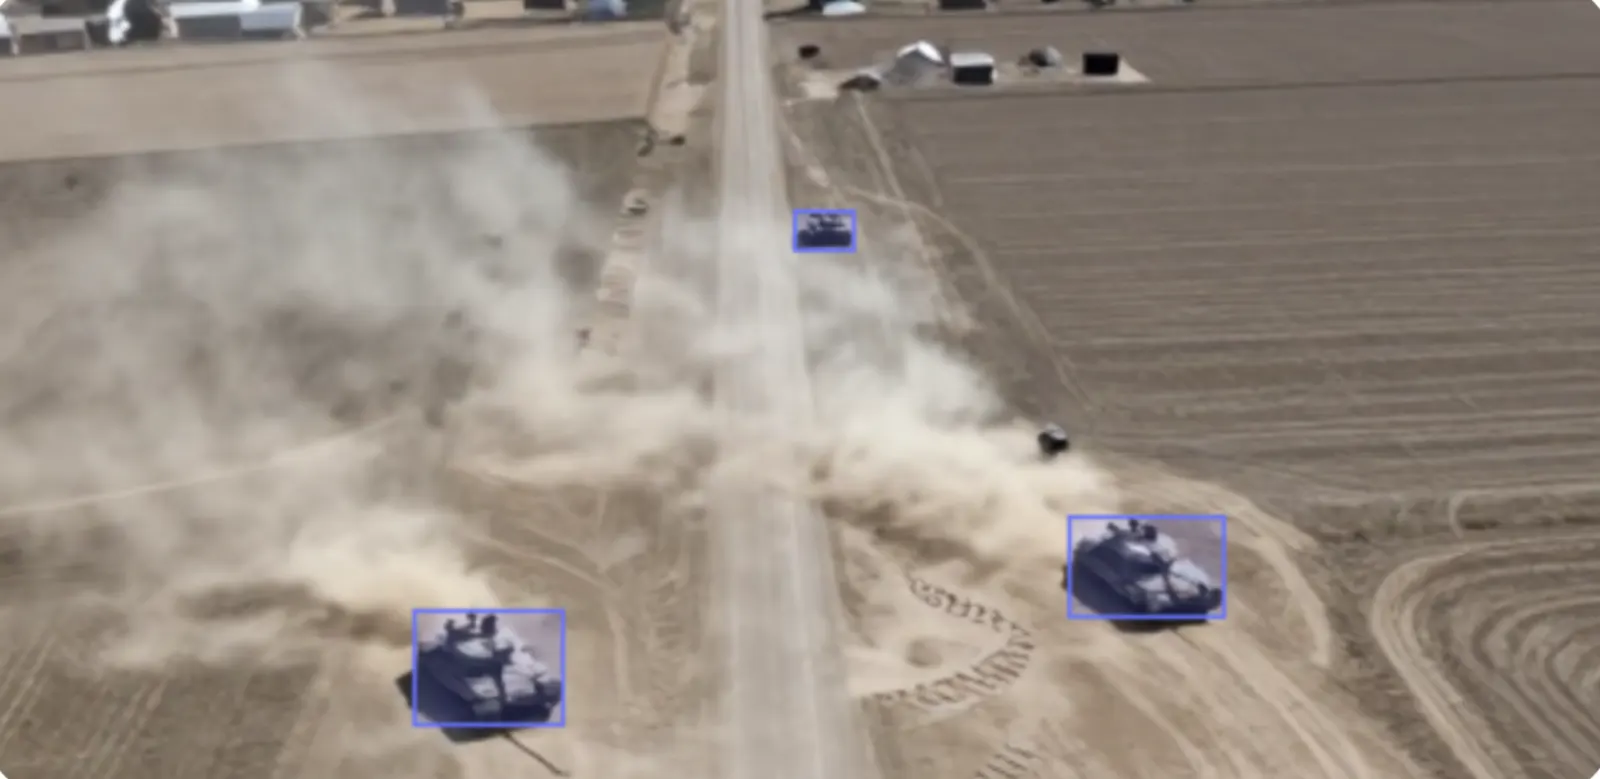
Three tanks, one drone, zero classified footage. Every pixel is synthetic and every bounding box is exact.
If you've ever tried to train a computer vision model to recognize a main battle tank from a drone, you already know the joke. There is no dataset. There has never really been a dataset. Every serious defense team ends up scraping the same handful of Ukraine war clips off social media, cropping frames by hand, and quietly hoping nobody notices that half the labels were guessed by an intern.
That's not a training pipeline. That's a rumor with bounding boxes.
The reason the gap exists is boring and structural. Real tactical aerial footage of armored vehicles is one of three things: classified by a government, restricted by an operator, or filmed under airspace conditions that would get a civilian pilot arrested. That leaves academic researchers and startup engineers with essentially no training data for one of the most obvious defense AI use cases on the planet. Our new UAV & Aerial View: Battle Tank Detection Dataset is what we built to fix that.
A drone that can't tell a tank from a tractor is not autonomous. It's a very expensive kite with a camera.
Why Ground-Level Datasets Don't Help
There are ground-level tank photos on the open web. Wikipedia has them. Defense expos post them. Model kit magazines are full of them. None of them are useful for a drone. A tank photographed from ten meters away at eye level and a tank photographed from a UAV at 300 meters altitude are, from a neural network's perspective, almost completely different objects. The silhouette collapses. The turret becomes a disc. The tracks disappear entirely. Even the shadow, which is often the strongest signal from altitude, doesn't exist in the ground-level shot in a form the model can transfer.
The angle matters more than the object. That's why aerial datasets are not optional for aerial detection, and why generic datasets like COCO or ImageNet fall over the moment you point a drone camera at the ground.
The Angles That Actually Matter
Real reconnaissance drones don't fly at one altitude or one pitch. A quadcopter doing perimeter recon might fly at 60 meters with a 30-degree oblique camera. A fixed-wing ISR platform might loiter at 400 meters with the gimbal pointed straight down at 90-degree nadir. A tactical loitering munition operates somewhere in between and adjusts constantly as it descends.
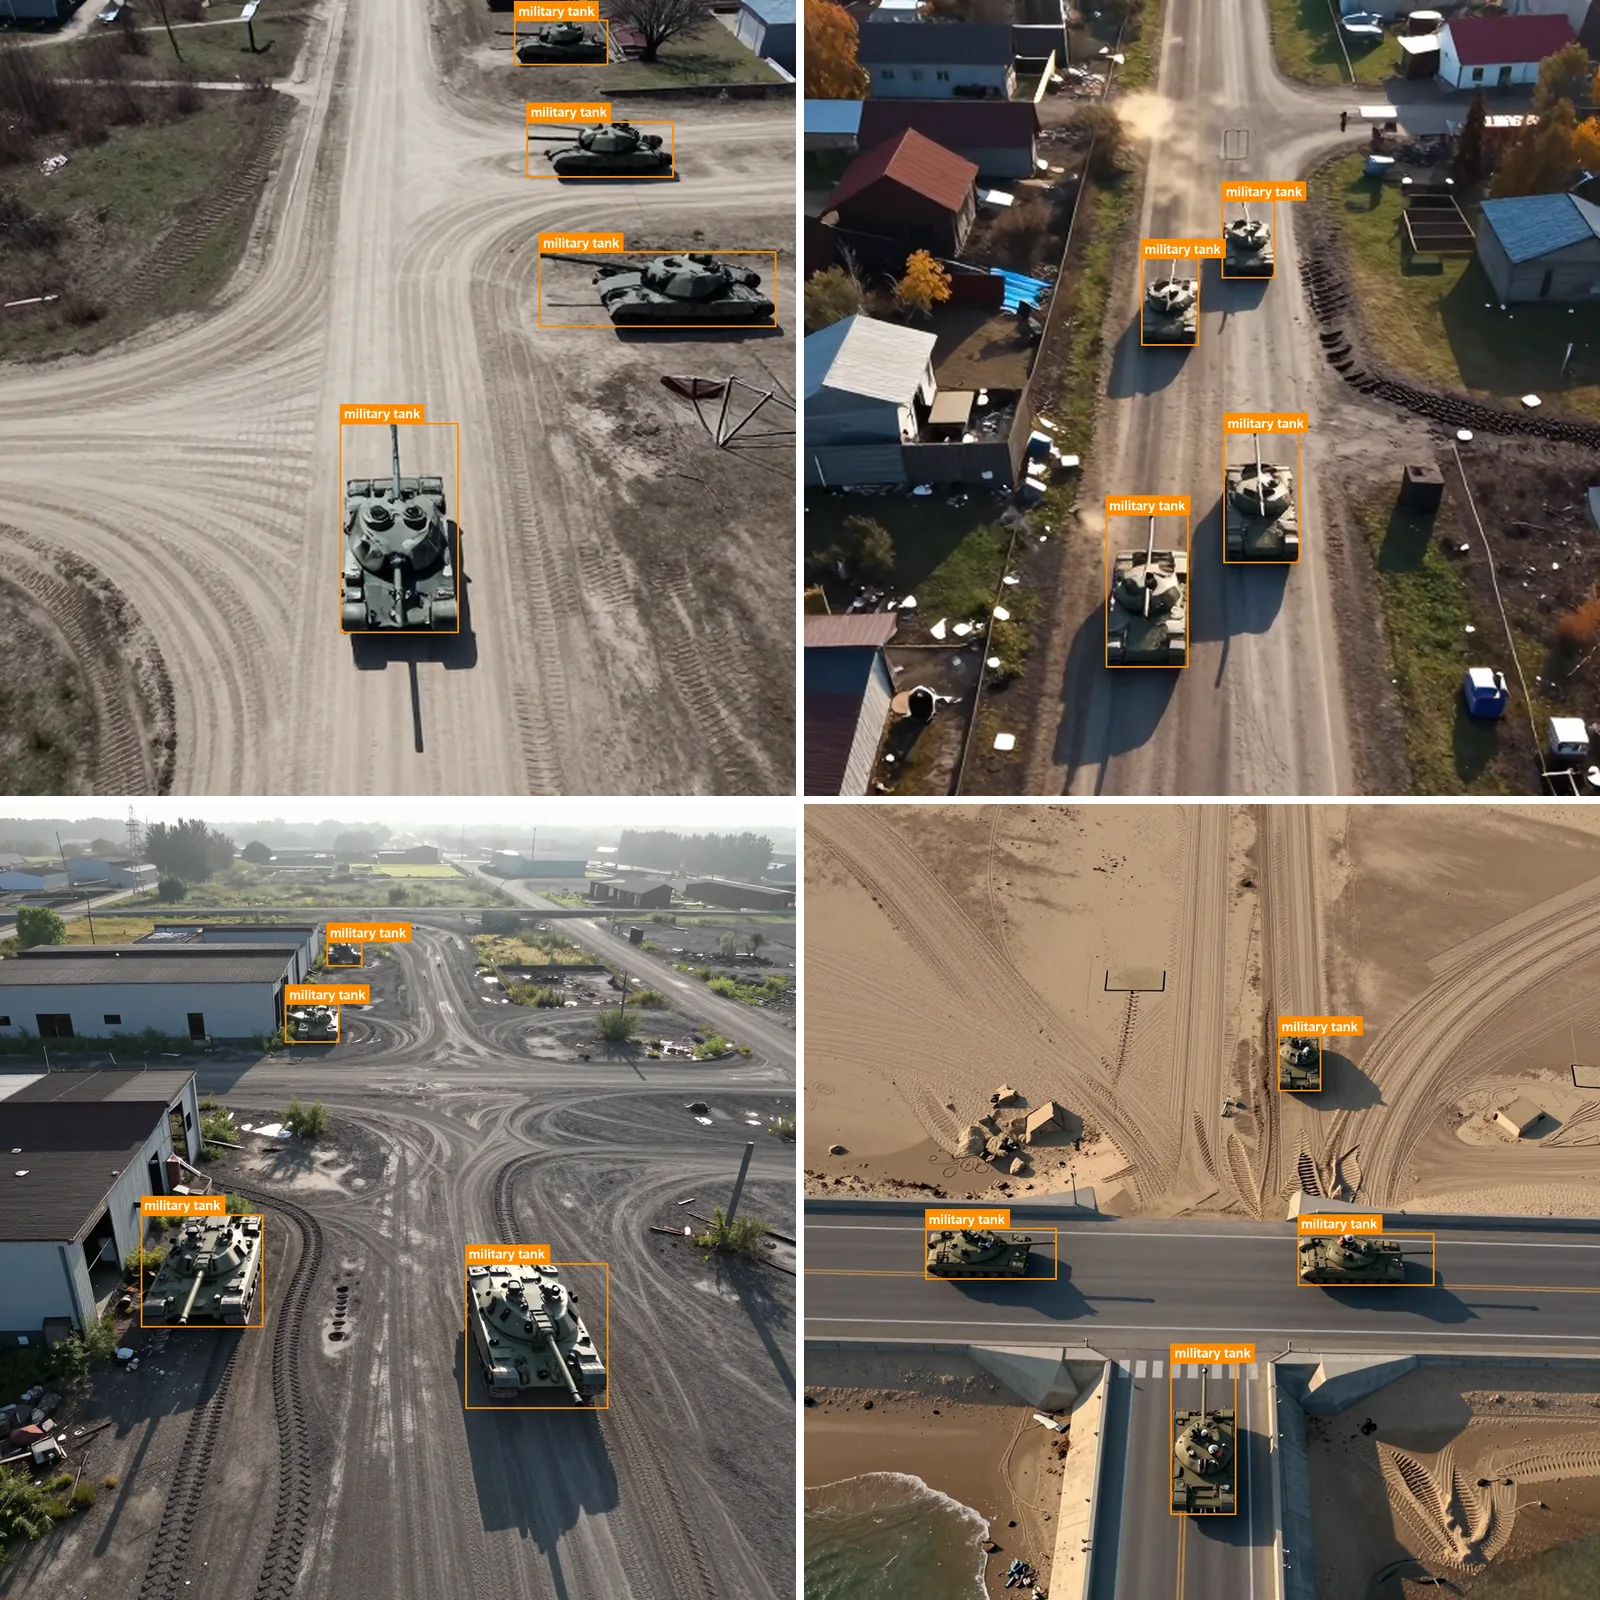
This dataset covers all of it. Every scene is rendered from a realistic UAV perspective sampled across that whole envelope, from shallow oblique flyovers where you can still see the side of the hull, to true top-down nadir views where the tank is essentially a rectangle with a barrel poking out of one side. Focal lengths vary. Altitudes vary. Atmospheric haze varies. So does the amount of dust kicked up by the vehicles themselves, which is a surprisingly consistent visual signature and a very useful learning signal for the model.
Three Theaters, One Class
The dataset spans three visually distinct environments on purpose. Desert terrain is the classic proving ground: hot, dusty, high contrast, minimal cover, and the kind of terrain where most of the world's public tank footage was filmed in the last twenty years. Eastern European village terrain is the opposite: cluttered roofs, narrow lanes, tree lines, and civilian structures that force the detector to learn geometric context rather than color histograms. Open agricultural fields sit in between, with long sightlines, plowed rows that mimic track patterns, and seasonal vegetation that changes what "background" even means.
We deliberately kept the class list short. One class: battle_tank. No infantry fighting vehicles, no artillery, no soft-skinned trucks. The point of a first release is a clean, high-signal baseline that a defense team can fine-tune from without arguing about class hierarchies. Everything else can be added as a supplementary package once the base detector is solid.
Why Annotations From Simulation Beat Human Labels
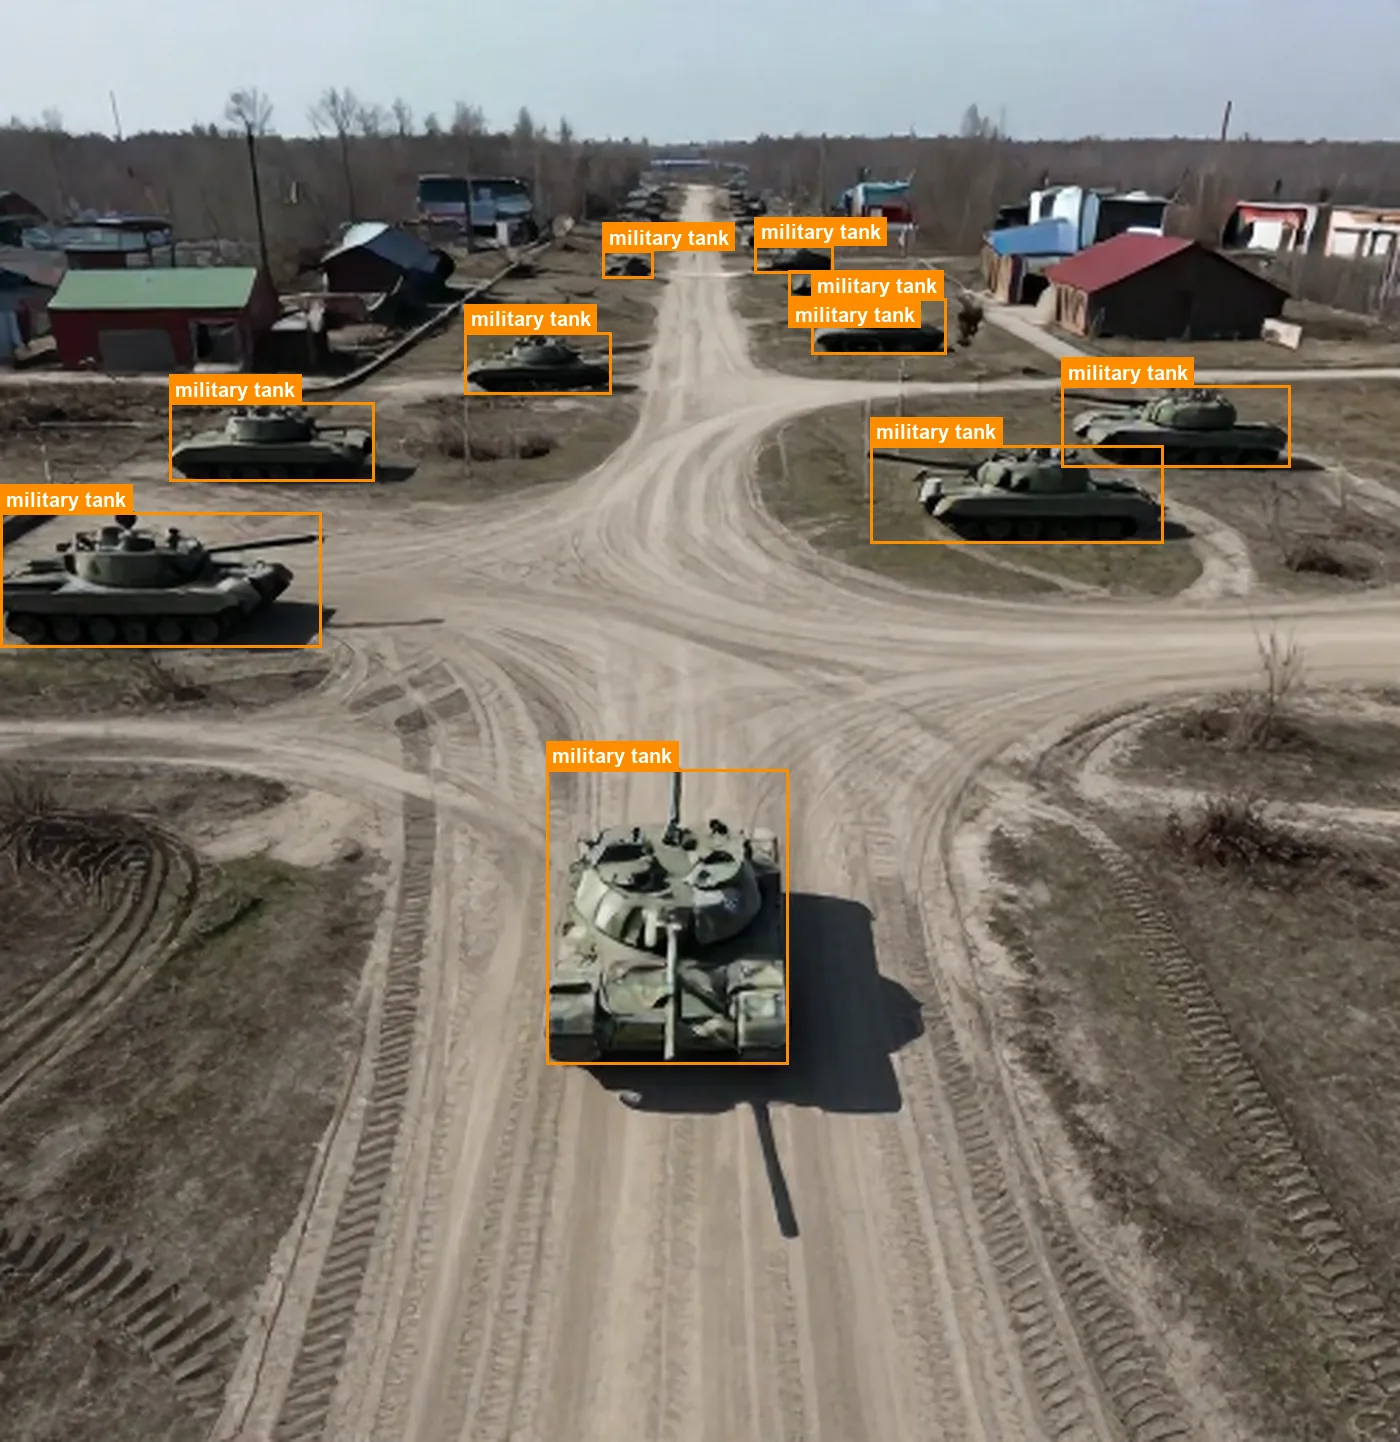
Hand-labeling aerial imagery is where a lot of defense CV projects quietly die. Bounding a tank from 300 meters up is genuinely hard for a human. The turret rotation matters. The gun barrel pitch matters. Cast shadows can double the apparent footprint. Dust plumes can hide the rear third of the vehicle. Two annotators looking at the same frame will often draw noticeably different boxes, and that noise is exactly what a small-object detector cannot afford.
Because every frame in this dataset is generated by simulation, we know where the tank is before we draw it. Bounding boxes are computed from the 3D geometry, not eyeballed from pixels. Turret and barrel orientation are baked into the annotation. Shadows are excluded from the box, and dust is not counted as vehicle. Every label is consistent because the same math produced all of them.
What's In the Package
The open-source sample on Kaggle is 164 YOLO-annotated images, which is enough to fine-tune an existing YOLOv8 or YOLO11 checkpoint and get an honest first benchmark on aerial armored vehicle detection. The full package is 3,000 images, balanced across the three theaters and the full range of UAV pitches.
Ready-to-train folder layout
Standard images/ and labels/ split, with normalized YOLO .txt annotations. A single-class data.yaml is included so training starts with one command.
Sim2Real friendly
The rendering pipeline was tuned for domain adaptation research, not for beauty shots. Sensor noise, motion blur, atmospheric haze, and lens distortion are all present in realistic amounts.
Fully legal, fully synthetic
No real airspace footage, no real vehicles, no classified sensor signatures. The free sample is non-commercial; commercial defense R&D needs the commercial licence.
Practical Notes for Training
- Train at higher input resolution. Tanks at true nadir from 400 meters are small objects. Higher input sizes (for example 1280px instead of 640px) usually help small objects; check it on your own validation set.
- Don't skip the shallow oblique subset. It's tempting to filter to nadir only, but the oblique frames teach the model what a partially visible hull looks like, which pays off during descent and approach.
- Use a real domain adaptation step. If your target sensor is thermal or low-resolution SD video, this dataset is your source domain and you should still plan a small real-world adaptation set. Sim2Real is a bridge, not a shortcut.
- Mix in aerial hard negatives. Combines, harvesters, and shipping containers from an overhead view can trigger false positives. Adding overhead hard negatives like these alongside the base training set reduces that noise.
Who Should Actually Use This
- Defense integrators building autonomous reconnaissance or ISR payloads on tactical UAVs.
- Loitering munition and counter-armor teams that need a clean training signal for terminal-phase target confirmation.
- Academic Sim2Real researchers looking for a geometrically perfect source domain to test domain adaptation techniques against real drone footage.
- Simulation and wargaming vendors who need pre-annotated aerial content for training embedded AI models.
Get the Data
The 164-image free sample is non-commercial: CC BY-NC 4.0 on Hugging Face, CC BY-NC-SA 4.0 on Kaggle. It's enough to prove the approach works and to fine-tune an existing YOLO checkpoint. The dataset is licensed as 1,000 images (research $149, commercial $590); for the full 3,000-image package, additional vehicle classes (IFVs, APCs, artillery), thermal or FLIR sensory layers, or custom camera specifications, get in touch. We render to spec.
You can wait for someone to declassify real drone footage of armored vehicles, or you can start training tomorrow. One of those options is realistic.
Related reading: Airport Drone Threat Dataset and Military Drone Swarm Dataset.
Related Articles
Airport Drone Detection Dataset: Training AI for Aviation's Toughest Challenge
Open-source synthetic dataset for detecting rogue drones at airports.
Drone Swarm Detection Dataset: Solving Counter-UAS Saturation Attacks
Open-source synthetic dataset for detecting high-density drone swarms and saturation attacks.
PPE compliance detection: why hard-hat presence labels aren't enough
Labelling hard hats and safety vests as worn, worn wrong or missing, from CCTV angles.